Infrastructure·
NVIDIA Isaac ROS 5.0 Brings Agentic AI to Open‑Source Robotics
The latest Isaac ROS release adds AI‑agent workflows, GPU‑accelerated libraries and support for ROS Lyrical on Ubuntu 24.04, enabling faster development and deployment of perception‑heavy robotic systems.
Key Technical Enhancements
Isaac ROS 5.0 debuted at ROSCon in Toronto as a set of GPU‑accelerated packages built on the ROS framework, aiming to merge traditional robotics development with AI‑agent capabilities.
The release adds support for ROS Lyrical running on Ubuntu 24.04, and NVIDIA collaborated with the Open Source Robotics Alliance to contribute a standard data‑handling interface that lets robotics software move efficiently across CPUs, GPUs and other accelerators, with a CUDA‑based example showing how to harness the Jetson platform.
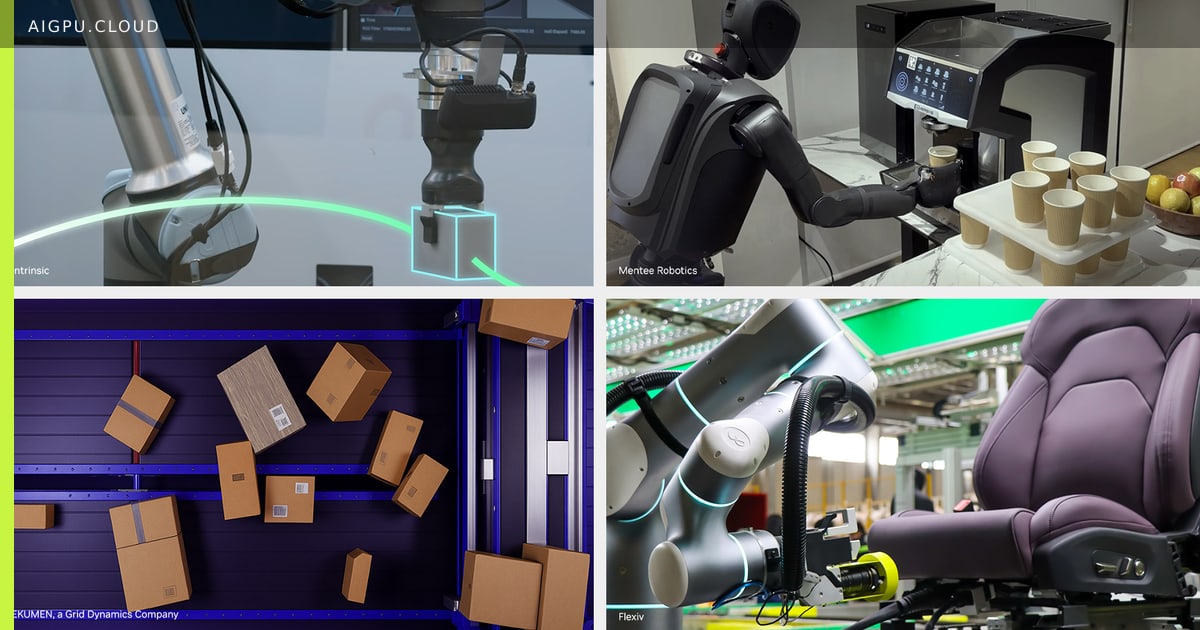
New agent‑ready skills include a FoundationStereo fine‑tuning tool that lets an AI agent adapt stereo perception models to specific cameras and environments, a FoundationPose inference library that tracks object pose up to 5.5× faster, and a standalone pick‑and‑place skill that connects detection, depth estimation and pose output for flexible manipulation workflows.
Why it matters for GPU / AI infrastructure: these upgrades reduce inference latency, improve utilization of Jetson GPUs, and allow developers to offload repetitive coding tasks to AI agents, thereby accelerating the pipeline from concept to deployed robot while keeping the open‑source ROS ecosystem intact.
- aigpu
- ai gpu
- ai gpu cloud
- aigpu dubai
- isaac ros
- robotics
- gpu acceleration
- ros lyrical
- ai agents
- jetson
By AiGpu Editorial · Editorial rewrite based on public reporting (NVIDIA Blog)
← All articles